




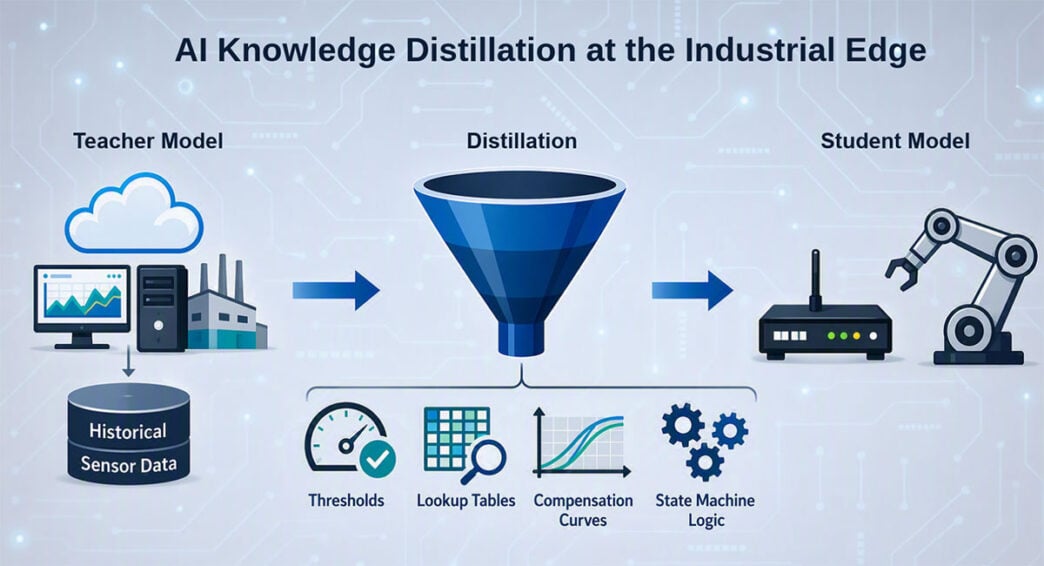
Many industrial Edge AI systems need to make decisions locally, right where the analog sensor data arrives. The challenge is that a lot of these endpoints simply cannot host large AI models, move high volumes of data, or lean on a processor for every response. Knowledge distillation offers a practical way around this. During development, a high-compute teacher model learns the behaviour you want. That behaviour is then reduced to compact rules or decision functions, and those functions run on a small student device out in the field. The result is distilled AI behaviour that maps neatly into configurable mixed-signal hardware, placed directly in the sensor signal path.
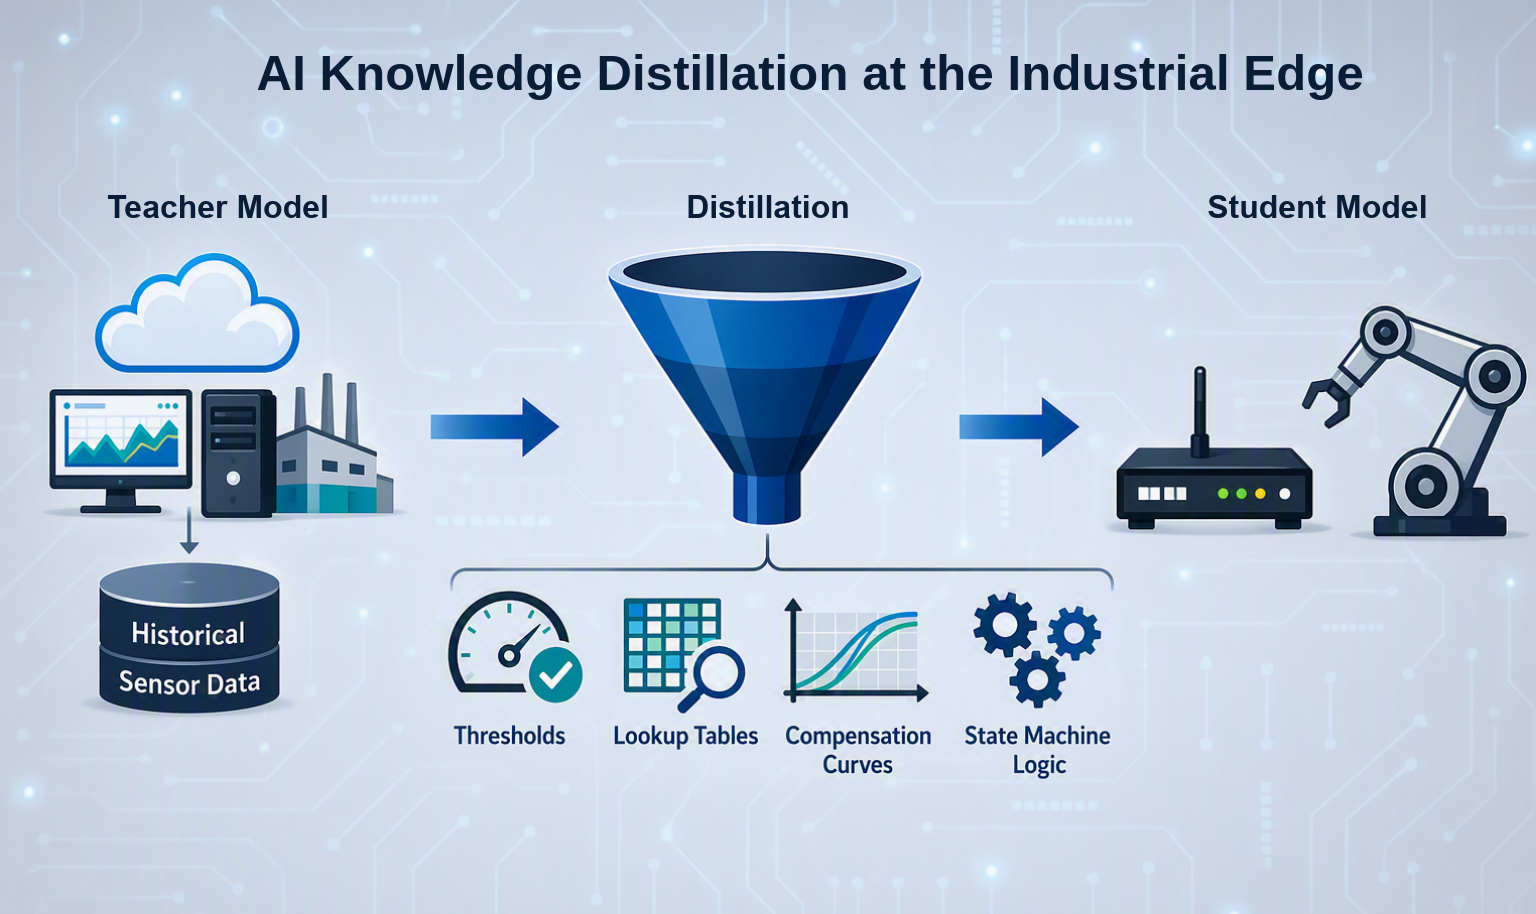
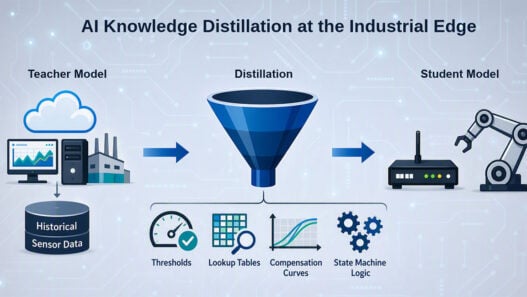
Figure 1 shows the teacher-student workflow. The teacher learns from development data, distillation converts that learning into compact rules, and the student applies those rules locally at the industrial Edge.
Teacher-student model in AI
In teacher-student architecture, the teacher model is used during development to extract decision behaviour from measured system data. Typical inputs may include sensor history, operating conditions, calibration data, environmental variation, fault signatures, and known outcomes. The teacher output is not necessarily deployed directly; instead, it is used to derive implementable decision logic for the endpoint.
The student device implements the distilled behaviour in the deployed system. Depending on the application, the distilled behaviour may be represented as calibrated thresholds, gain or offset correction, lookup tables, linearisation curves, timing windows, state-machine transitions, event counters, voting logic, or control-output rules.
Student device functional requirements
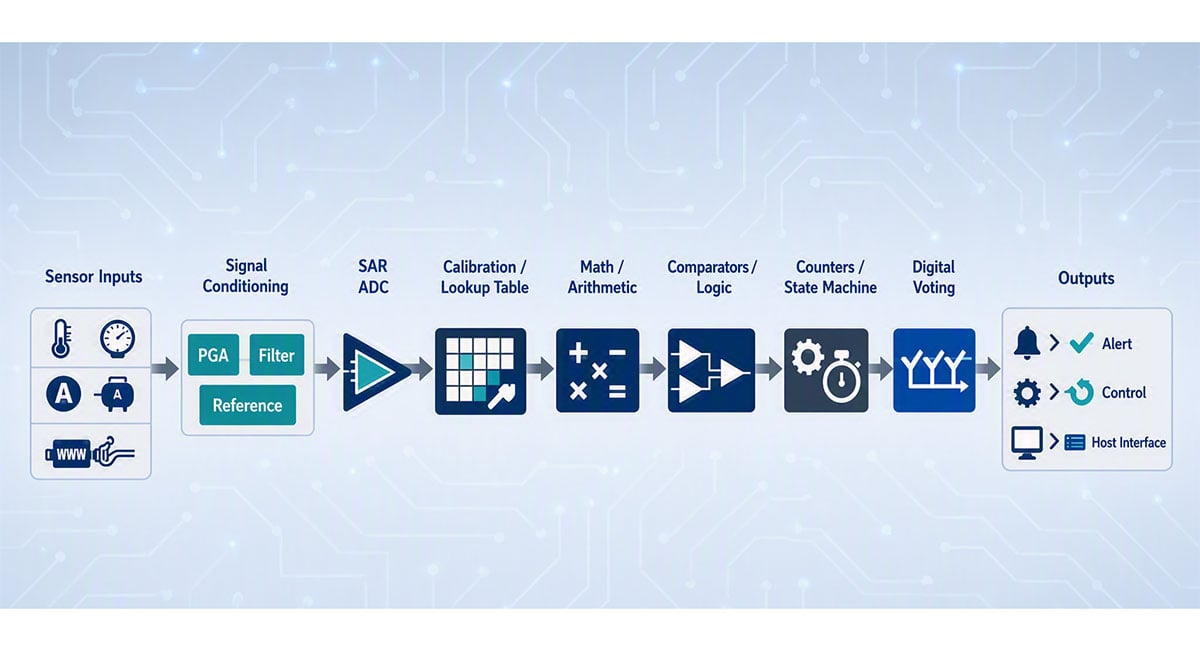
A student device for industrial Edge AI must work directly with real-world analog signals and carry out its distilled behaviour within a predictable time. At the signal-chain level, this requires accurate acquisition, signal conditioning, conversion, local correction, event qualification, and deterministic output control.
The functions involved often include programmable gain, filtering, averaging, sensor linearization, lookup table correction, arithmetic operations, threshold comparison, hysteresis, counters, timers, state logic, fault outputs, and reporting back to the host. Together they let the distilled behaviour run close to the point of measurement, rather than living entirely in system firmware.
It helps to think of the student device as a local home for learned behaviour, rather than as just a sensor, an ADC, or a processor. Its real value comes from how much of the measurement, correction, decision, and response loop it can handle locally and predictably.
Industrial example: predictive monitoring
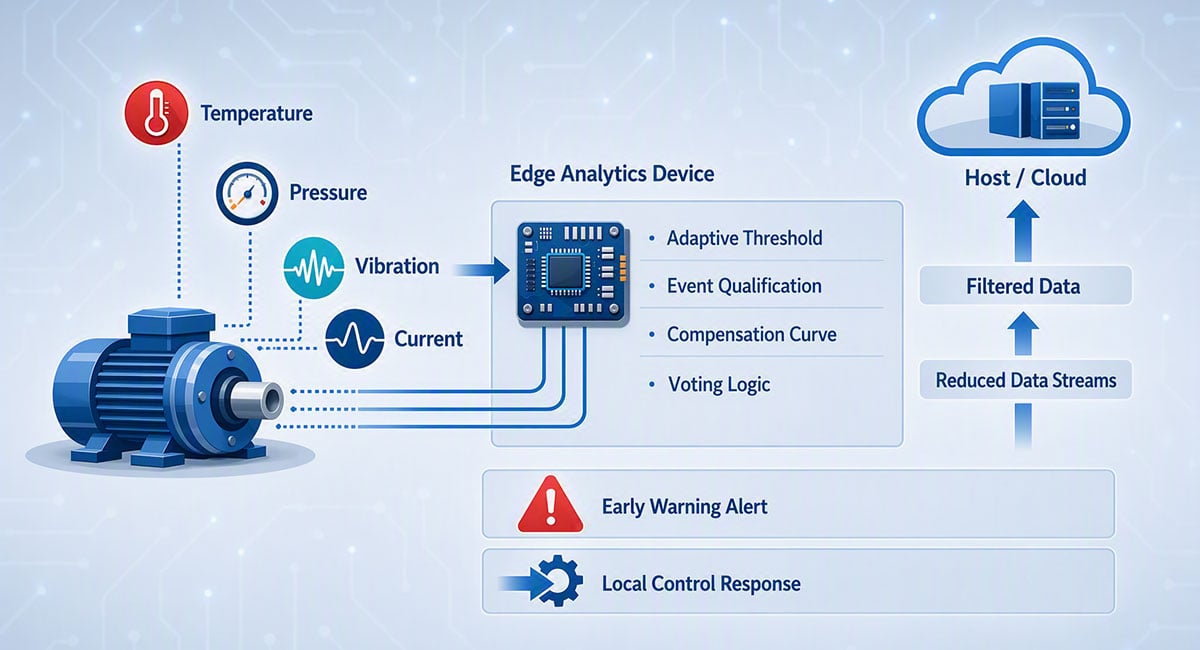
In a predictive-monitoring application, a teacher model may analyse temperature, pressure, vibration, current, duty cycle, and operating history gathered from motors, pumps, actuators, or process sensors. What it learns becomes a set of endpoint rules, for example, temperature-dependent gain adjustment, nonlinear sensor correction, fault qualification using two thresholds, timed event validation, or thresholds that adapt to load.
Running these rules locally means there is no need to stream raw data to a host processor or a cloud service for every decision. The endpoint can qualify events right at the sensor interface, generate local interrupts or drive control outputs, and forward only relevant status, fault, or measurement data upstream.
Implementation trade-offs: MCU-centric vs. configurable ADC architecture
Any practical design must spread analog acquisition, correction, decision logic, timing, and fault response across the signal chain. A standalone ADC will digitise the input signal, but compensation curves, adaptive thresholds, event qualification, voting logic, and local control still must be implemented in external circuitry or firmware.
An MCU can handle decision logic, yet it usually needs a set of analog-front-end functions before conversion. Sensor excitation, gain scaling, input filtering, precision conversion, reference generation, protection, and comparators can all add components, firmware dependencies, timing variation, and validation effort.
An MCU with an integrated ADC reduces package count, but the ADC path may still be limited by input range, reference accuracy, resolution, sample sequencing, and analog-front-end flexibility. Correction, timing-window detection, event confirmation, voting logic, and output control remain primarily firmware-managed.
A configurable ADC with integrated mixed-signal resources moves more implementation functions into the measurement path. Local correction, thresholding, hysteresis, timing, voting logic, and output control can be implemented as hardware-configured behaviour, reducing processor load, external components, response latency, and firmware validation scope.
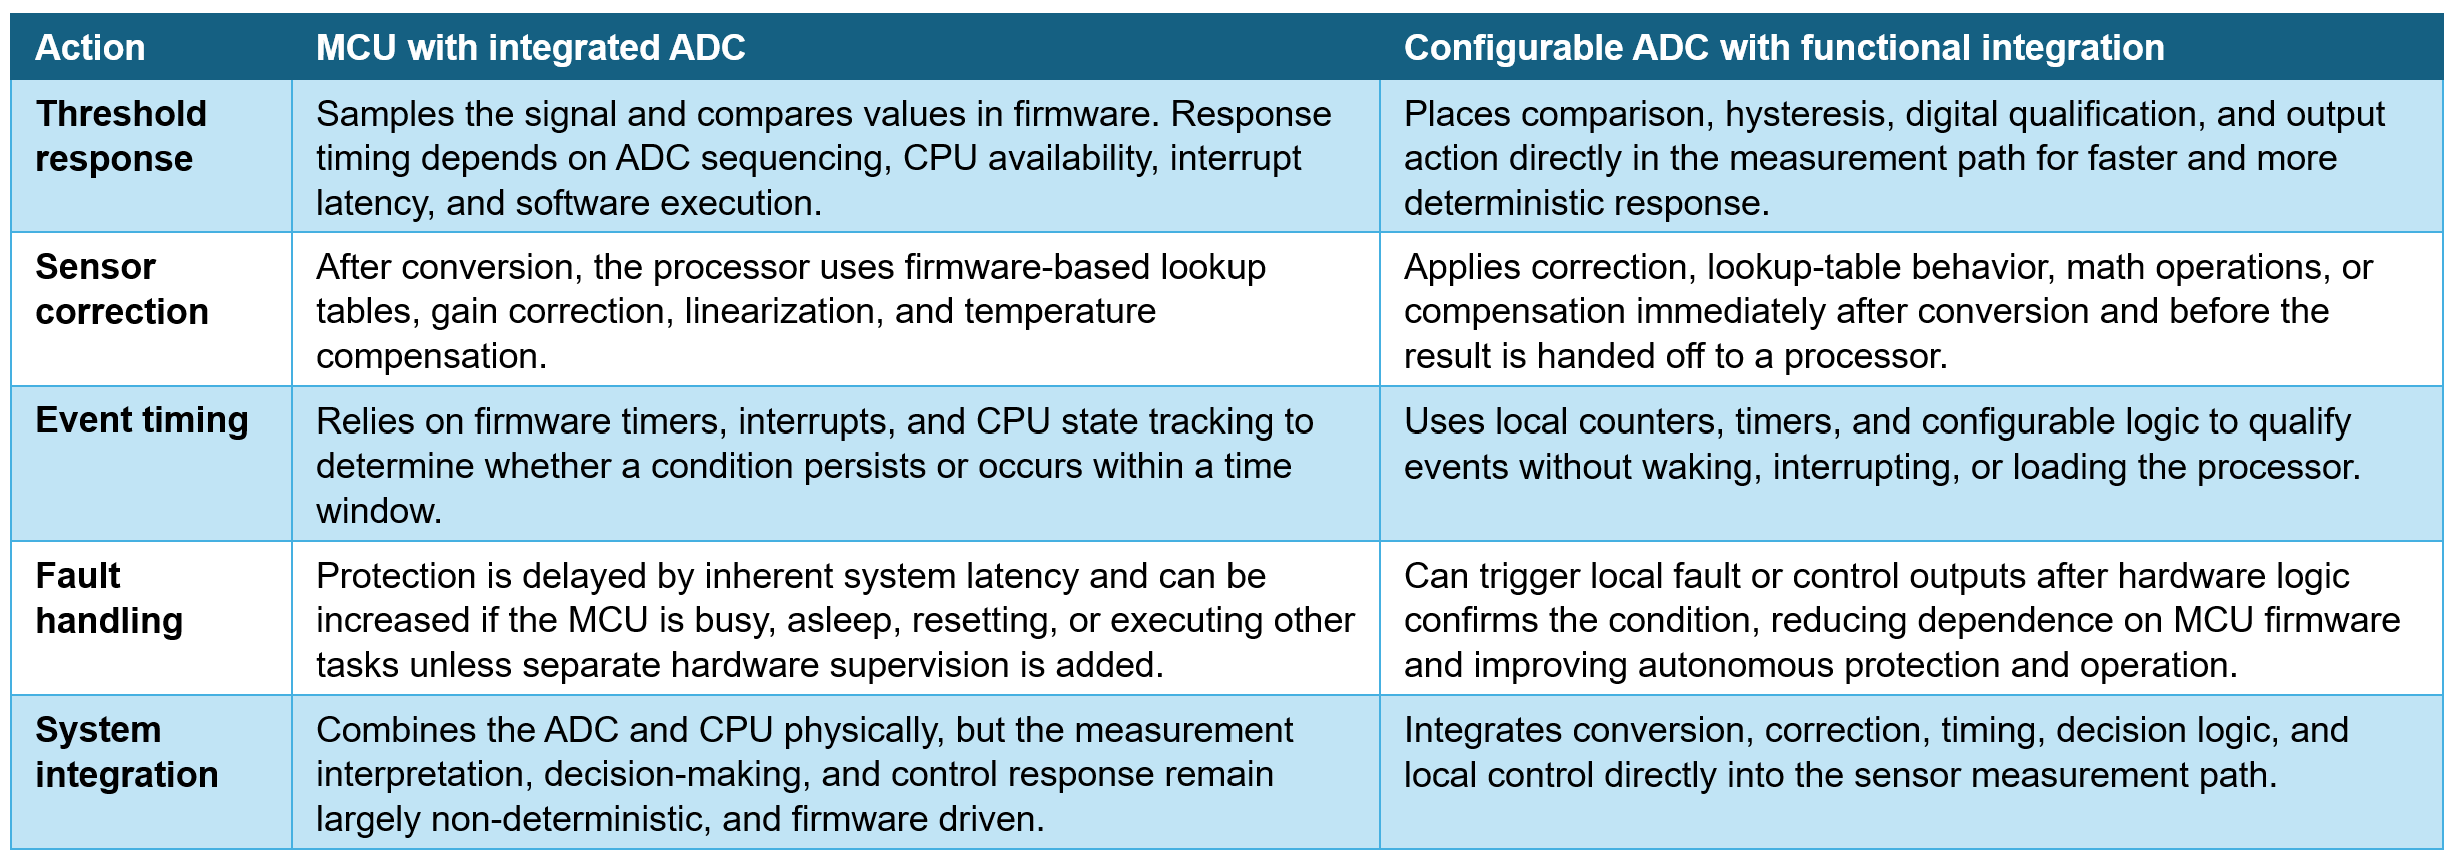
So, the real architectural question is not simply where conversion happens, but where correction, qualification, and response take place. For distilled Edge AI behaviour, bringing these functions closer to the sensor can lower cost while improving latency, determinism, power, and overall robustness.
ADCPAK as a configurable student-device implementation
ADCPAK provides a configurable mixed-signal implementation path for distilled student-device behaviour. By integrating acquisition, conditioning, conversion, correction, decision logic, timing, and local control together, it reduces how many functions you must spread across discrete analog circuitry and MCU firmware.
Relevant ADCPAK resources may include SAR ADC conversion, programmable gain, DACs, comparators, voltage references, memory tables, arithmetic resources, counters, timers, lookup tables, digital logic, and serial interfaces. These resources support common distilled behaviour functions such as compensated measurement, nonlinear transfer correction, adaptive thresholds, event-window qualification, autonomous fault output, and compact host reporting.
In this implementation, the teacher model defines the desired decision behaviour during development, while ADCPAK implements the distilled result as configurable hardware. This enables the endpoint to execute selected AI-derived behaviour without deploying a full neural-network model or continuously involving the host processor.
The primary benefit of the design is efficiency: fewer external components, simpler firmware, lighter use of the processor, lower processor utilisation, faster local response, and a smaller validation surface for time-critical protection and monitoring functions.
Design example: local motor condition monitoring
Consider a motor drive endpoint that monitors winding temperature and phase current to detect abnormal load or early fault conditions. During development, a teacher model analyses logged sensor data across load, ambient temperature, duty cycle, and known fault cases to identify practical endpoint rules for correction, qualification, and response.
In the deployed system, ADCPAK can acquire the sensor inputs, apply gain or offset correction, use lookup-table behaviour for temperature compensation, compare the corrected values against adaptive thresholds, and qualify the result with local counters or timers. Once a condition is confirmed, it can raise a fault output, interrupt the host MCU, or update a status register over the serial interface.
This implementation keeps time-critical measurement and protection behaviour close to the sensor while allowing the MCU to manage higher-level diagnostics, communications, and system policy. The result is a practical student-device partition: ADCPAK executes distilled local behaviour, and the host processor handles supervisory functions.
Key takeaway
For industrial Edge AI endpoints, the objective is often not to run the largest model locally, but to implement the most useful distilled behaviour near the sensor. Knowledge distillation provides a practical method for converting AI-derived behaviour into correction, thresholding, timing, state-logic, and control-output rules that can execute in compact endpoint hardware.
ADCPAK supports this implementation model by integrating acquisition, conditioning, conversion, correction, qualification, and local response in configurable mixed-signal hardware. This partition keeps deterministic behaviour close to the sensor while reducing data movement, firmware burden, processor utilisation, external circuitry, and validation scope.